The Unseen Challenge of Building Walking Robots: A Deep Dive into Actuator Design
If you’ve ever marveled at the fluidity of a walking robot, you might assume the magic lies in its programming or design. But personally, I think the real hero is often overlooked: the actuator. It’s the unsung workhorse that translates digital commands into physical movement. Yet, what many people don’t realize is that creating a compact, powerful, and efficient actuator for walking robots is one of the most stubborn engineering challenges of our time. Let me explain why this matters—and why it’s far more fascinating than it sounds.
The Actuator Dilemma: Why Walking Robots Aren’t Just ‘Legged Machines’
Walking robots, unlike their wheeled counterparts, demand actuators that mimic the precision and power of biological muscles. But here’s the catch: muscles are nature’s masterpiece—compact, energy-efficient, and capable of delivering force in a way that no current technology can fully replicate. Robots, on the other hand, rely on actuators that are often bulky, slow, or inefficient. This puts walking robots at a disadvantage, especially when you consider that actuators must be placed directly at the joints, adding weight and complexity.
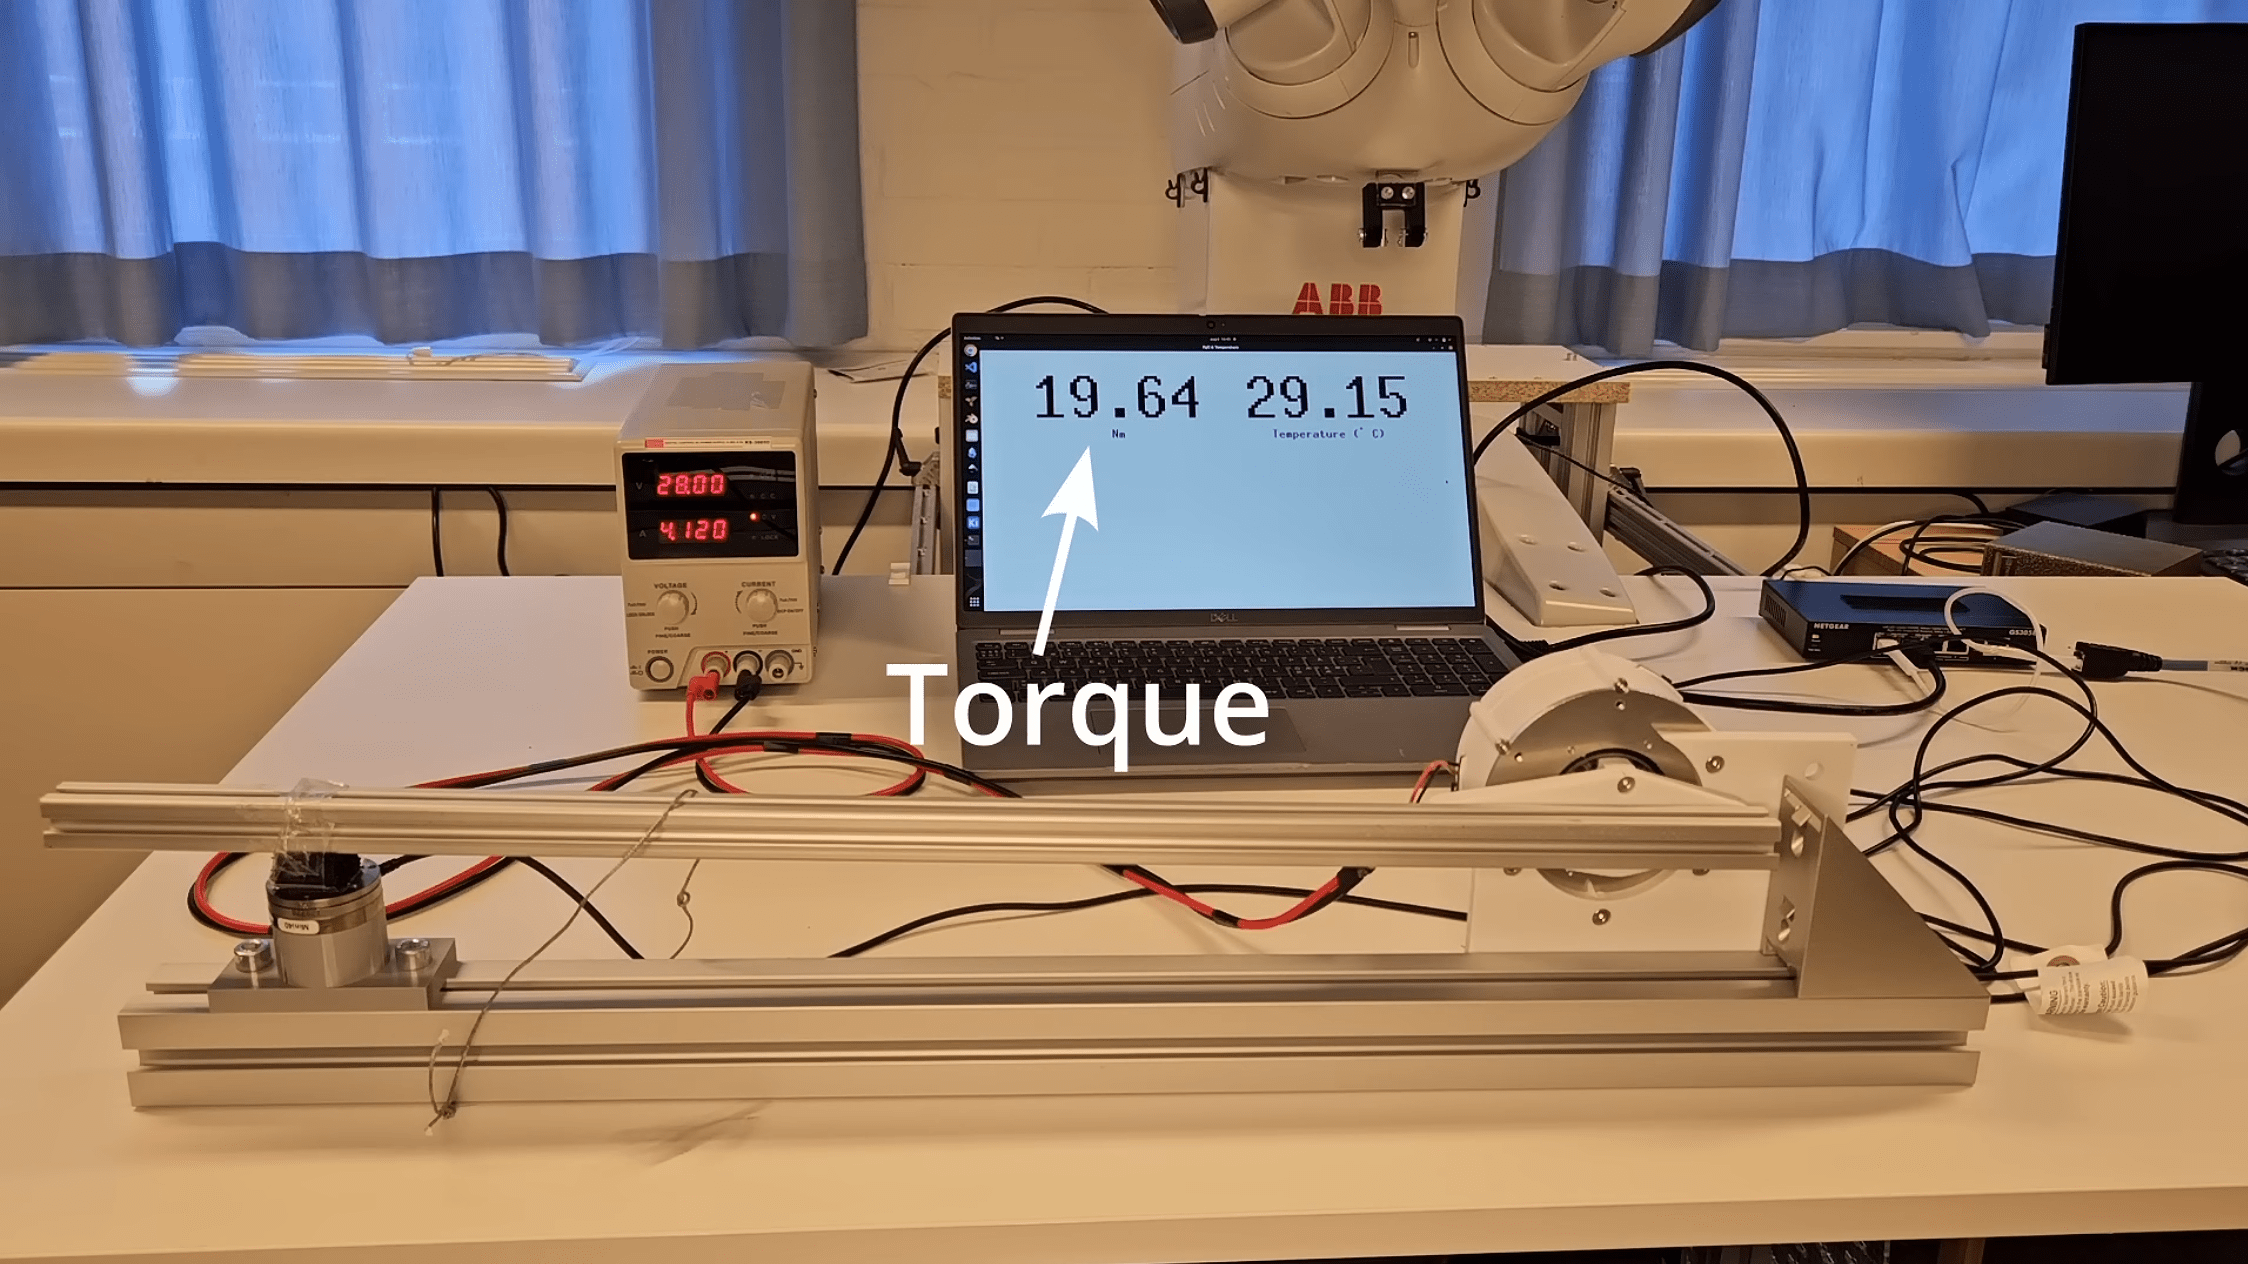
Take the case of [Food for Robots], a creator who tackled this problem head-on. His goal? To build a lightweight, backdrivable actuator capable of producing 20 Newton-meters of torque. What makes this particularly fascinating is his iterative approach. His first attempt, a 3D-printed actuator, failed under stress. But instead of giving up, he pivoted to machining aluminum, switching from a Capstan drive to a planetary gearbox. This raises a deeper question: how often do we underestimate the value of iteration in innovation?
The Planetary Gearbox: A Tiny Marvel with Big Implications
One thing that immediately stands out is the use of a planetary gearbox in [Food for Robots]’ design. By placing the gearbox inside the stator and stacking gears, he maximized strength within a small form factor. This isn’t just clever engineering—it’s a testament to the power of constraints. When you’re limited by size and materials, you’re forced to think creatively.
From my perspective, this highlights a broader trend in robotics: the shift toward compact, integrated systems. As robots become more agile and versatile, every millimeter and gram counts. A detail that I find especially interesting is how the gearbox sits inside the stator, almost like a Russian nesting doll. It’s a reminder that innovation often comes from rethinking how components interact, not just improving them in isolation.
The Torque Conundrum: When More Isn’t Always Better
Here’s where things get really intriguing. [Food for Robots] initially struggled to achieve 20 Newton-meters of torque, even after doubling the stator’s thickness. The culprit? An increase in windings had inadvertently raised resistance, canceling out any power gains. What this really suggests is that optimization isn’t just about adding more—it’s about understanding how every change ripples through the system.
This isn’t unique to robotics. In my opinion, it’s a universal lesson in engineering: every modification has unintended consequences. What many people don’t realize is that even small tweaks can disrupt the delicate balance of a design. It’s a humbling reminder that we’re not just building machines—we’re navigating complex systems where every decision matters.
The Broader Implications: Why Actuators Are the Key to the Future of Robotics
If you take a step back and think about it, actuators are the linchpin of robotics. Without them, robots would be little more than static sculptures. But as we push the boundaries of what robots can do—whether it’s walking, grasping, or interacting with humans—actuators will need to evolve. This isn’t just about making them stronger or smaller; it’s about making them smarter.
Personally, I think the next frontier in actuator design lies in biomimicry. Nature has already solved many of the problems we’re grappling with. Why not learn from it? For instance, muscles don’t just contract—they adapt to the task at hand, using only the energy they need. If we can replicate that level of efficiency, we’re not just building better robots; we’re redefining what’s possible.
Final Thoughts: The Quiet Revolution in Robotics
As I reflect on [Food for Robots]’ journey, one thing is clear: the progress in actuator design is incremental, but its impact is profound. Each failure, each iteration, brings us closer to robots that can move with the grace and efficiency of living creatures. What this really suggests is that the future of robotics isn’t just about AI or sensors—it’s about the humble actuator.
So, the next time you see a walking robot, don’t just admire its movements. Think about the engineering marvels hidden within its joints. Because, in my opinion, that’s where the real magic happens.